吉林大学学报(工学版) ›› 2026, Vol. 56 ›› Issue (10): 2606-2616.doi: 10.13229/j.cnki.jdxbgxb.20250374
• 交通运输工程·土木工程 • 上一篇
网联交叉口信号相位与车辆轨迹联合优化方法
蒋贤才( ),马星,郭子豪
- 东北林业大学 土木与交通学院,哈尔滨 150040
Joint optimization method of signal phase and vehicle trajectory at connected intersections
Xian-cai JIANG(),Xing MA,Zi-hao GUO
- School of Civil Engineering and Transportation,Northeast Forestry University,Harbin 150040,China
摘要:
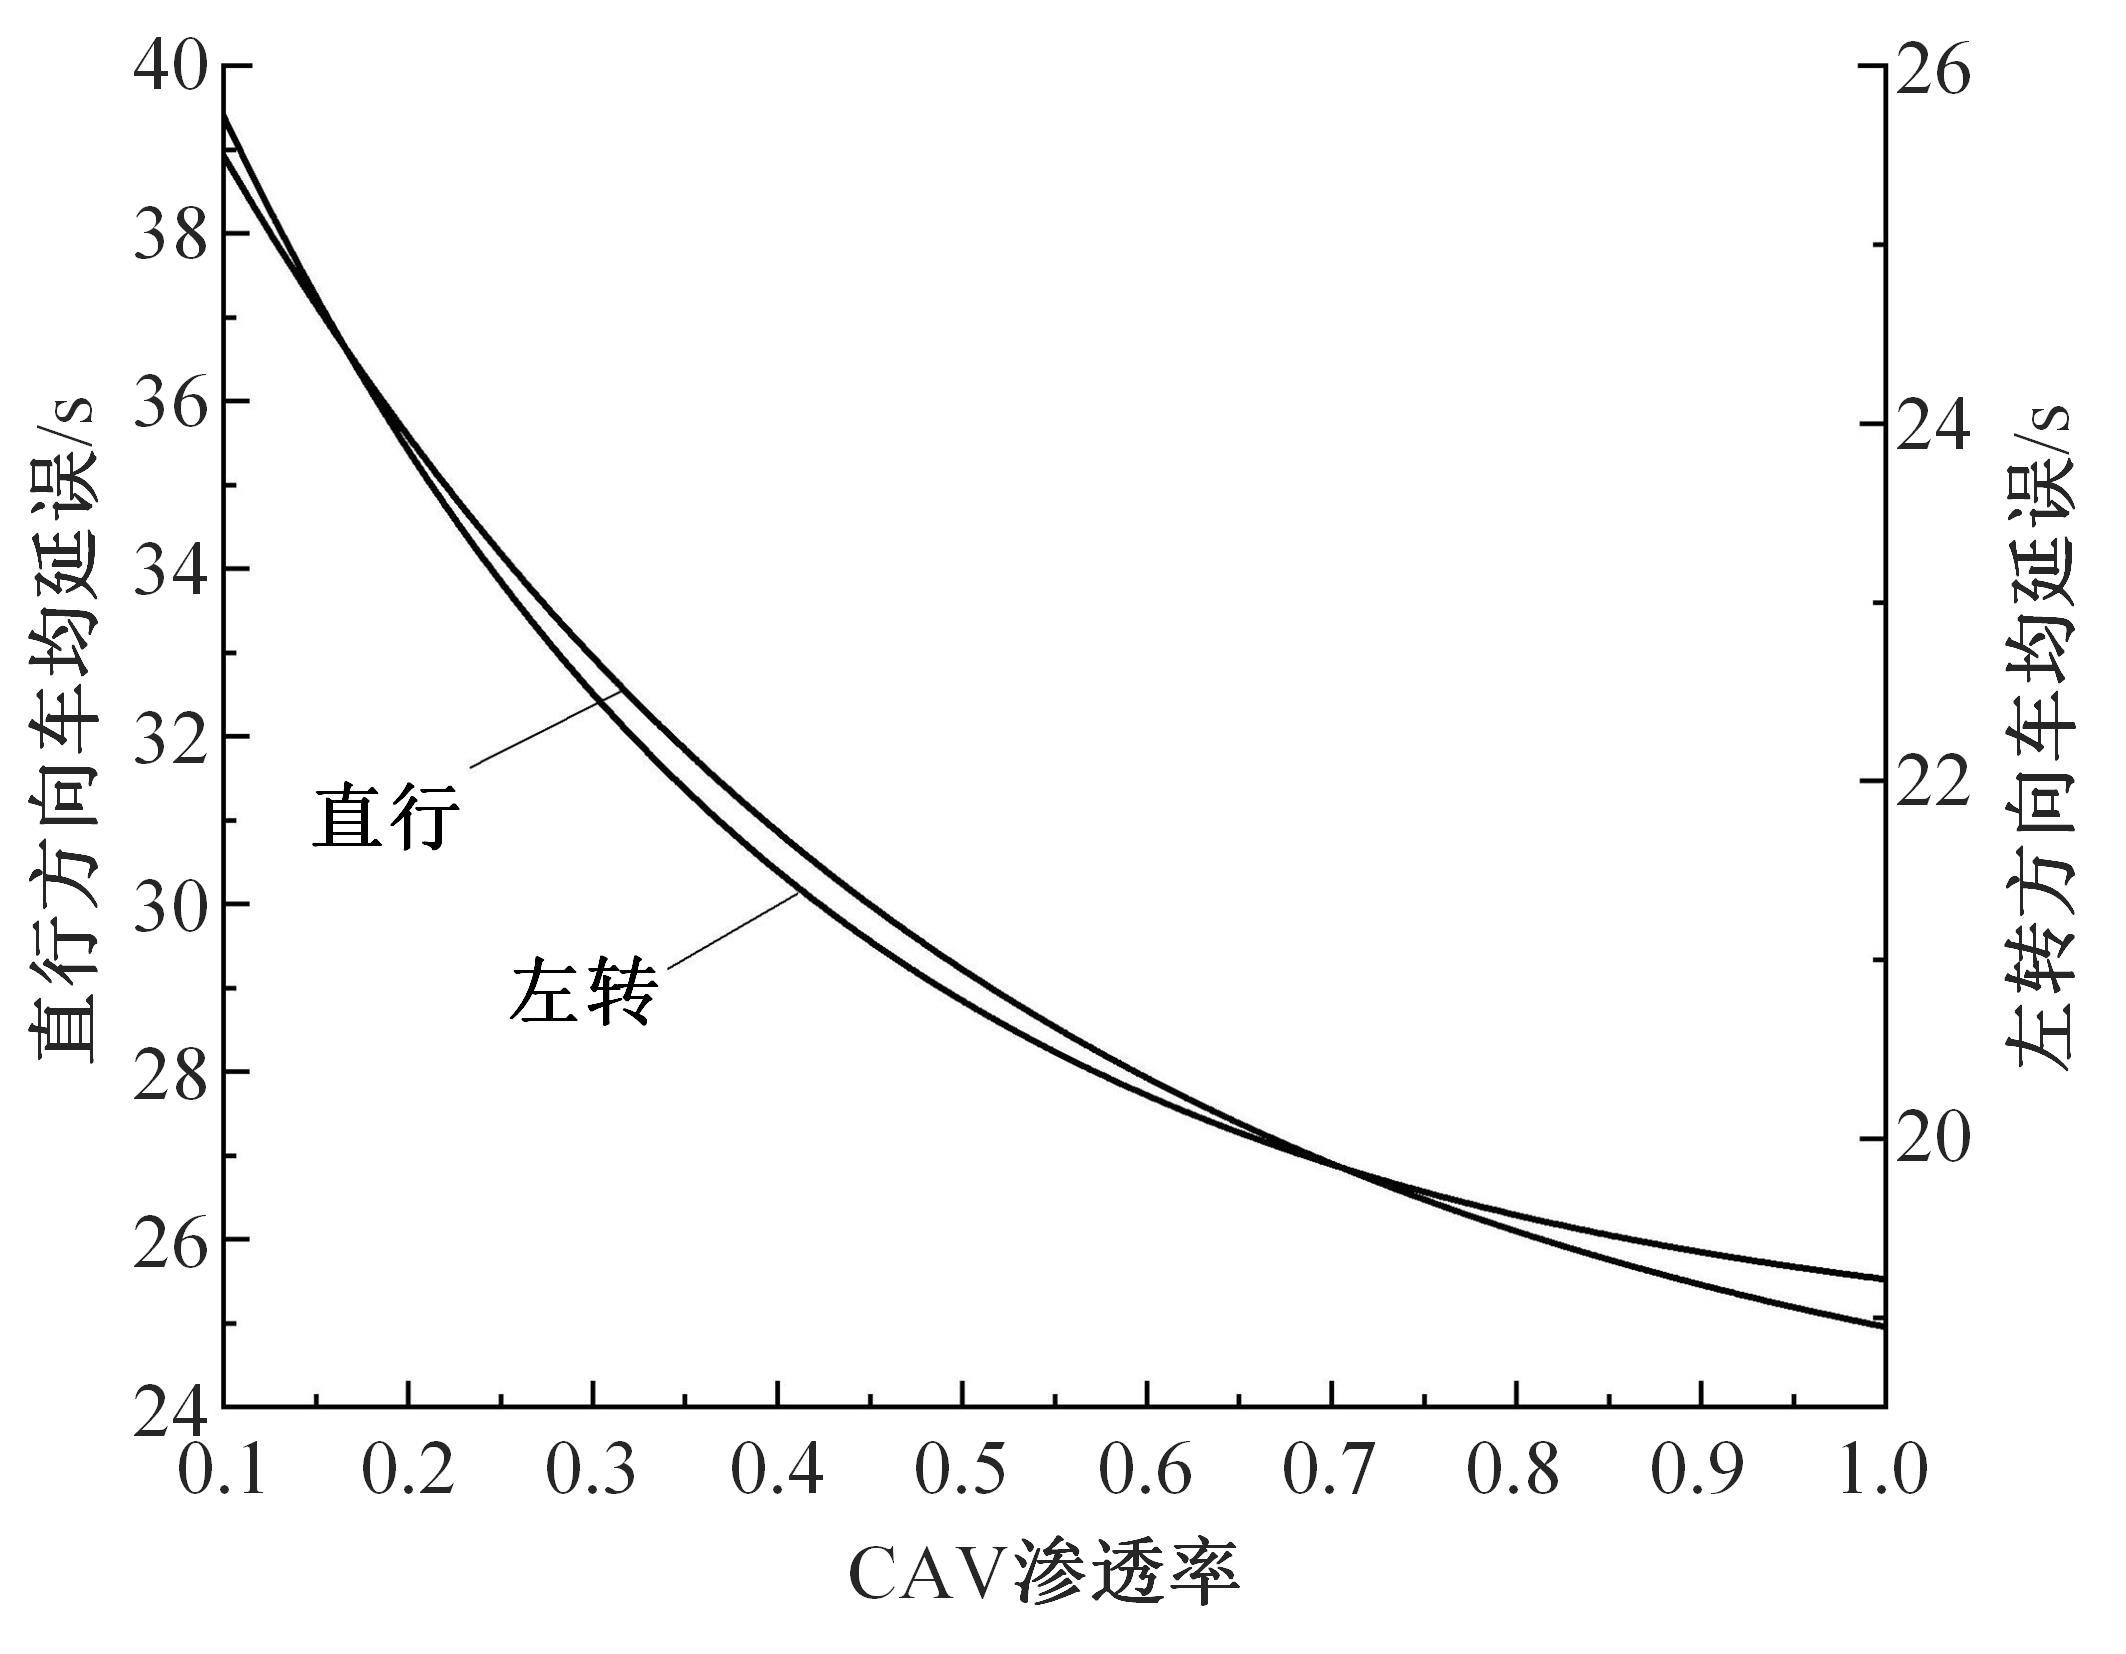
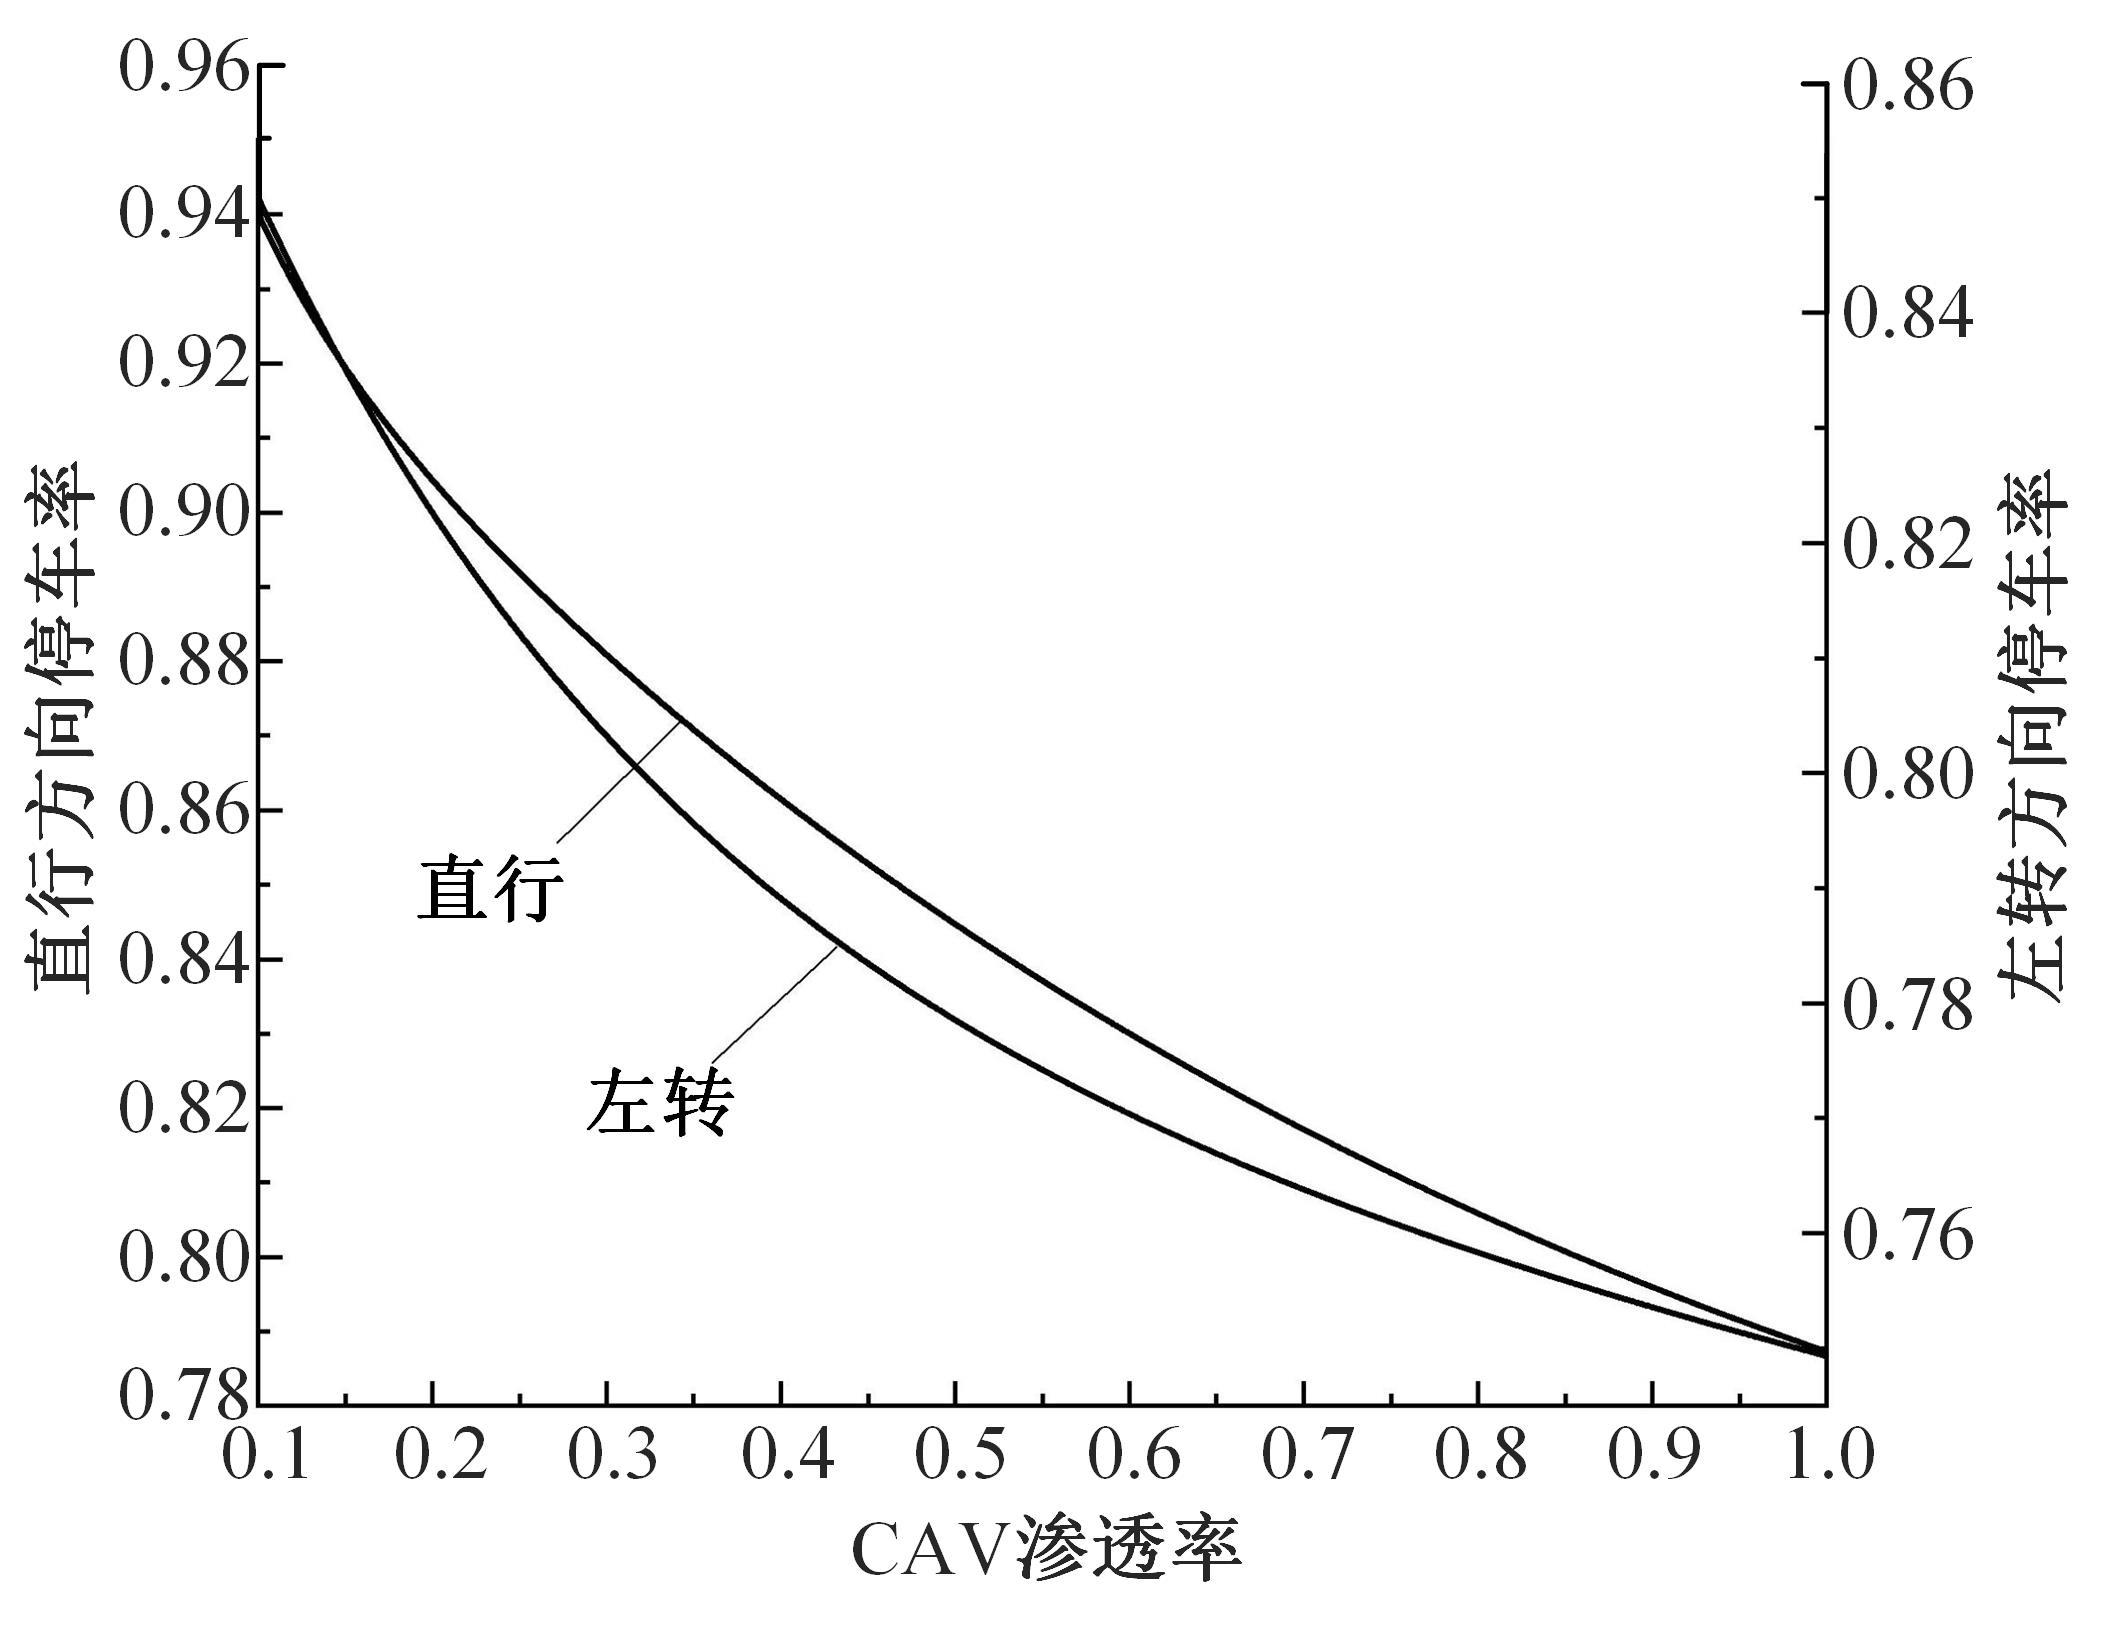
为改善传统信号控制滞后响应交通流实时波动的状况,提出了一种网联环境下交叉口信号相位与车辆轨迹联合优化方法。通过协同优化车辆行驶轨迹与信号相位配时方案,动态适配交通流波动,达到提升交叉口通行效率的目的。仿真结果表明:相较于无轨迹优化的信号控制策略,该方法可降低6.45%~16.42%的车均延误以及2.36%~8.39%的停车率;在交通流随机波动较大的场景下,本文方法较混合整数线性规划协同优化方法性能更稳定。进一步分析表明,网联车渗透率越高,本文方法的控制效果越显著。
中图分类号:
- U491

| [1] | Liu C, Liu Z, Xu Z, et al. A multistep cooperative lane change strategy for connected and autonomous vehicle platoons departing from dedicated lanes[J]. Transportation Research Part C: Emerging Technologies, 2024, 165: 104720. |
| [2] | Shang Y, Zhu F, Jiang R, et al. Trajectory planning at a signalized road section in a mixed traffic environment considering lane-changing of CAVs and stochasticity of HDVs[J]. Transportation Research Part C: Emerging Technologies, 2024, 158: 104441. |
| [3] | Duan L, Wei Y, Dong S, et al. Centralized vehicle trajectory planning on general platoon sorting problem with multi-vehicle lane changing[J]. Transportation research part C: Emerging Technologies, 2023, 154: 104273. |
| [4] | Tajalli M, Niroumand R, Hajbabaie A. Distributed cooperative trajectory and lane changing optimization of connected automated vehicles: freeway segments with lane drop[J]. Transportation Research Part C: Emerging Technologies, 2022, 143: 103761. |
| [5] | Liu Q, Zhang K, Li M, et al. Integrated optimization of traffic signal timings and vehicle trajectories considering mandatory lane-changing at isolated intersections[J]. Transportation Research Part C: Emerging Technologies, 2024, 163: 104614. |
| [6] | Yao S, Zhou Y, Friedrich B, et al. Planning trajectories for connected and automated vehicle platoon on curved roads: a two-dimensional cooperative approach[J]. Transportation Research Part C: Emerging Technologies, 2024, 165: 104718. |
| [7] | 蒲云, 徐银, 刘海旭, 等. 考虑多车影响的智能网联车跟驰模型[J]. 吉林大学学报:工学版, 2024, 54(5): 1285-1292. |
| Pu Yun, Xu Yin, Liu Hai-xu,et al. An improved car⁃following model for connected and automated vehicles considering impact of multiple vehicles[J]. Journal of Jilin University(Engineering and Technology Edition), 2024, 54(5): 1285-1292. | |
| [8] | 姚昌宇, 柳祖鹏, 何雅琴, 等. 基于NEMA双环相位与合流相位的感应控制策略[J]. 公路交通科技, 2021, 38(3): 105-112. |
| Yao Chang-yu, Liu Zu-peng, He Ya-qin, et al. Inductive control strategy based on NEMA double-loop phase and confluence phase[J]. Journal of Highway and Transportation Research and Development, 2021, 38(3): 105-112. | |
| [9] | 何烈云, 周妍, 黄少泽, 等. 叠加放行信号控制方式适用条件及效益评价[J]. 重庆交通大学学报: 自然科学版, 2023, 42(1): 113-119. |
| He Lie-yun, Zhou Yan, Huang Shao-ze, et al. Application conditions and benefit evaluation of superimposed release signal control mode[J]. Journal of Chongqing Jiaotong University(Natural Science Edition), 2023, 42(1): 113-119. | |
| [10] | 刘晓佳, 李子木. 设置移位左转车道的不对称交通流信号交叉口设计及优化[J]. 重庆交通大学学报: 自然科学版, 2023, 42(2): 86-92, 143. |
| Liu Xiao-jia, Li Zi-mu. Design and optimization of asymmetric traffic flow signal intersection with shifted left-turn lane[J]. Journal of Chongqing Jiaotong University(Natural Science Edition), 2023, 42(2): 86-92, 143. | |
| [11] | 蒋贤才,于晨. 信号交叉口不对称交通流的优化控制方法[J]. 交通运输系统工程与信息, 2018, 18(6): 48-54. |
| Jiang Xian-cai, Yu Chen. The optimal control method of asymmetric traffic flow at signalized intersection[J]. Journal of Transportation Systems Engineering and Information Technology, 2018, 18(6): 48-54. | |
| [12] | 陆丽萍, 程垦, 褚端峰, 等. 基于竞争循环双Q网络的自适应交通信号控制[J]. 中国公路学报, 2022, 35(8): 267-277. |
| Lu Li-ping, Cheng Ken, Chu Duan-feng, et al. Adaptive traffic signal control based on dueling recurrent double Q network[J]. China Journal of Highway and Transport, 2022, 35(8): 267-277. | |
| [13] | Mo Z, Li W, Fu Y, et al. CVLight: Decentralized learning for adaptive traffic signal control with connected vehicles[J]. Transportation Research Part C: Emerging Technologies, 2022, 141: 103728. |
| [14] | 张玺君,聂生元, 李喆, 等. 基于自注意力机制的深度强化学习交通信号控制[J]. 交通运输系统工程与信息, 2024, 24(2): 96-104. |
| Zhang Xi-jun, Nie Sheng-yuan, Li Zhe, et al. Traffic signal control based on deep reinforcement learning based on self-attention mechanism[J]. Transportation Systems Engineering and Information, 2024, 24(2): 96-104. | |
| [15] | Li W, Zhu T, Feng Y. A cooperative perception based adaptive signal control under early deployment of connected and automated vehicles[J]. Transportation Research Part C: Emerging Technologies, 2024, 169: 104860. |
| [16] | Jiang X, Shang Q. A dynamic CAV-dedicated lane allocation method with the joint optimization of signal timing parameters and smooth trajectory in a mixed traffic environment[J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 24(6): 6436-6449. |
| [17] | Panwai S, Dia H. Comparative evaluation of microscopic car-following behaviour[J]. IEEE Transactions on Intelligent Transportation Systems, 2005, 6(3): 314-325. |
| [18] | 蒋贤才,徐慧智. 混合驾驶环境下交叉口空间资源动态控制方法[J]. 交通运输系统工程与信息, 2023, 23(6): 63-73. |
| Jiang Xian-cai, Xu Hui-zhi. Dynamic control method of intersection space resources in mixed driving environment[J]. Transportation Systems Engineering and Information, 2023, 23(6): 63-73. | |
| [19] | Liu M, Zhao J, Hoogendoorn S, et al. A single-layer approach for joint optimization of traffic signals and cooperative vehicle trajectories at isolated intersections[J]. Transportation Research Part C: Emerging Technologies, 2022, 134: 103459. |
| [1] | 王江锋,贺丹,罗冬宇,李云飞,齐崇楷,闫学东. 基于交互信息融合网络的车辆行驶风险预测模型[J]. 吉林大学学报(工学版), 2026, 56(8): 2177-2190. |
| [2] | 赵红星,刘书英,聂江龙,梁瑞艳,何瑞春. 考虑弯道条件的同质与异质交通流稳定性分析[J]. 吉林大学学报(工学版), 2026, 56(2): 393-406. |
| [3] | 郭洪艳,谢鸿楠,孟庆瑜. 单车智能条件下综合车辆运动状态的轨迹预测方法[J]. 吉林大学学报(工学版), 2026, 56(10): 2535-2545. |
| [4] | 单飞,李辉,孙浩,聂世刚,申忠虎. 基于改进simAM-YOLOv8的路面多病害识别方法[J]. 吉林大学学报(工学版), 2026, 56(1): 219-230. |
| [5] | 吴德华,陈荣峰. 智能网联客货混合交通流特性及集聚换道策略[J]. 吉林大学学报(工学版), 2025, 55(8): 2588-2596. |
| [6] | 侯越,郭劲松,林伟,张迪,武月,张鑫. 分割可跨越车道分界线的多视角视频车速提取方法[J]. 吉林大学学报(工学版), 2025, 55(5): 1692-1704. |
| [7] | 刘照霞,付锐,牛世峰. 基于极值理论与智能网联信息的超车风险评估[J]. 吉林大学学报(工学版), 2025, 55(3): 925-937. |
| [8] | 江晟,王祎笛,谢睿麟,夏淼磊. 基于门控循环网络时空关联的交通事故预测模型[J]. 吉林大学学报(工学版), 2025, 55(3): 954-962. |
| [9] | 李立,鲍宇健,杨文臣,楚庆玲,汪贵平. 路侧多源感知数据集规范化构建方法[J]. 吉林大学学报(工学版), 2025, 55(2): 529-536. |
| [10] | 王喆,范文波,刘昕,杨欢,宋现敏,杨柏婷. 基于改进开普勒优化算法的区域停车分配模型[J]. 吉林大学学报(工学版), 2025, 55(12): 3907-3917. |
| [11] | 程国柱,陈永胜. 智能网联环境下高速公路异质交通流建模及仿真[J]. 吉林大学学报(工学版), 2025, 55(11): 3583-3592. |
| [12] | 杨楠,肖军. 序列二次规划算法下城市智能交通运行节能优化控制[J]. 吉林大学学报(工学版), 2024, 54(8): 2223-2228. |
| [13] | 张辉,温鑫,陈海宇,黄世淳. 基于激光测距传感器的车辆轨迹全息感知方法[J]. 吉林大学学报(工学版), 2024, 54(8): 2378-2384. |
| [14] | 李立,吴晓强,杨文臣,周瑞杰,汪贵平. 基于路侧毫米波雷达的群体车辆目标识别与跟踪[J]. 吉林大学学报(工学版), 2024, 54(7): 2104-2114. |
| [15] | 杨秀建,贾晓寒,张生斌. 考虑汽车队列动态特性的混合交通流特性[J]. 吉林大学学报(工学版), 2024, 54(4): 947-958. |
|
||